Olli brings you your drink.
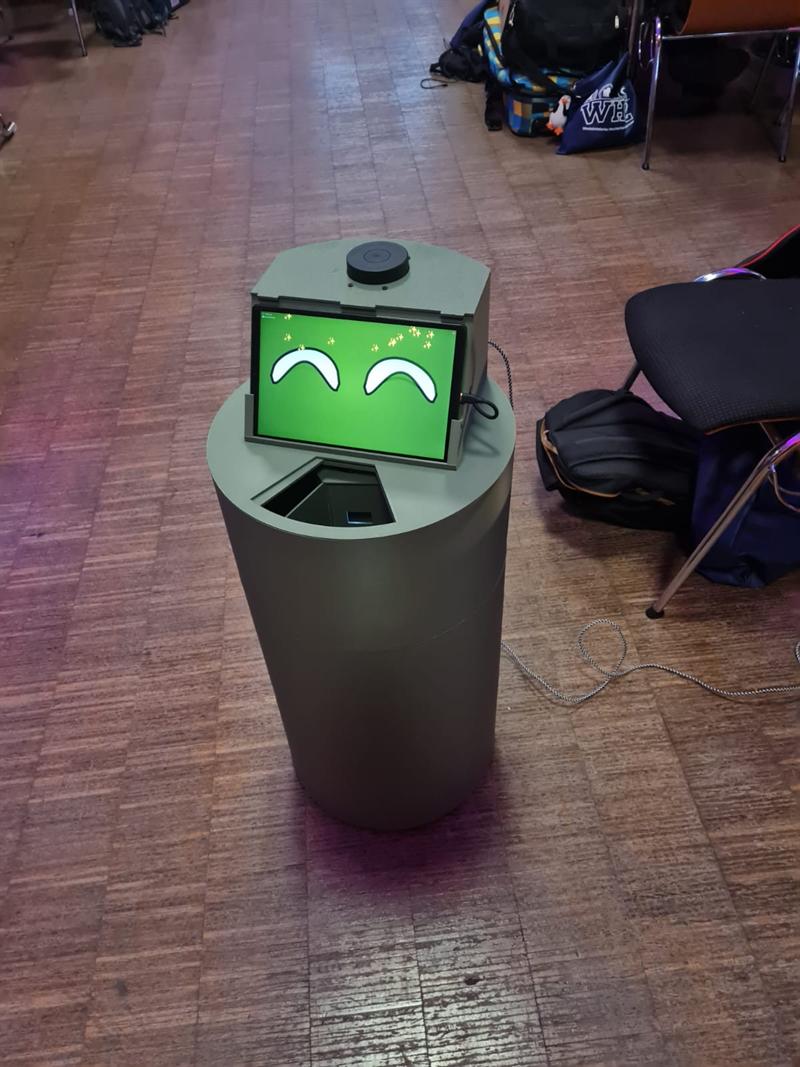
Olli is an autonomous drinks robot built for a 24-hour hackathon. You order from your phone at the table, Olli drives over and turns your compartment to the front.
How an order works
From phone to glass in four steps. Afterwards Olli drives back home on his own.
- 1
Pick table and drink
A QR code on the table opens the order page. Choose what you want to drink.
- 2
Olli sets off
He knows a map of the room, locates himself on it and plans the route to your table.
- 3
Your compartment turns to the front
The carousel has six compartments and brings exactly the right one into position.
- 4
Take your drink
A buzzer reminds you until the compartment is empty. Then it's on to the next order.
Olli on the move
Tests and drives from the night.
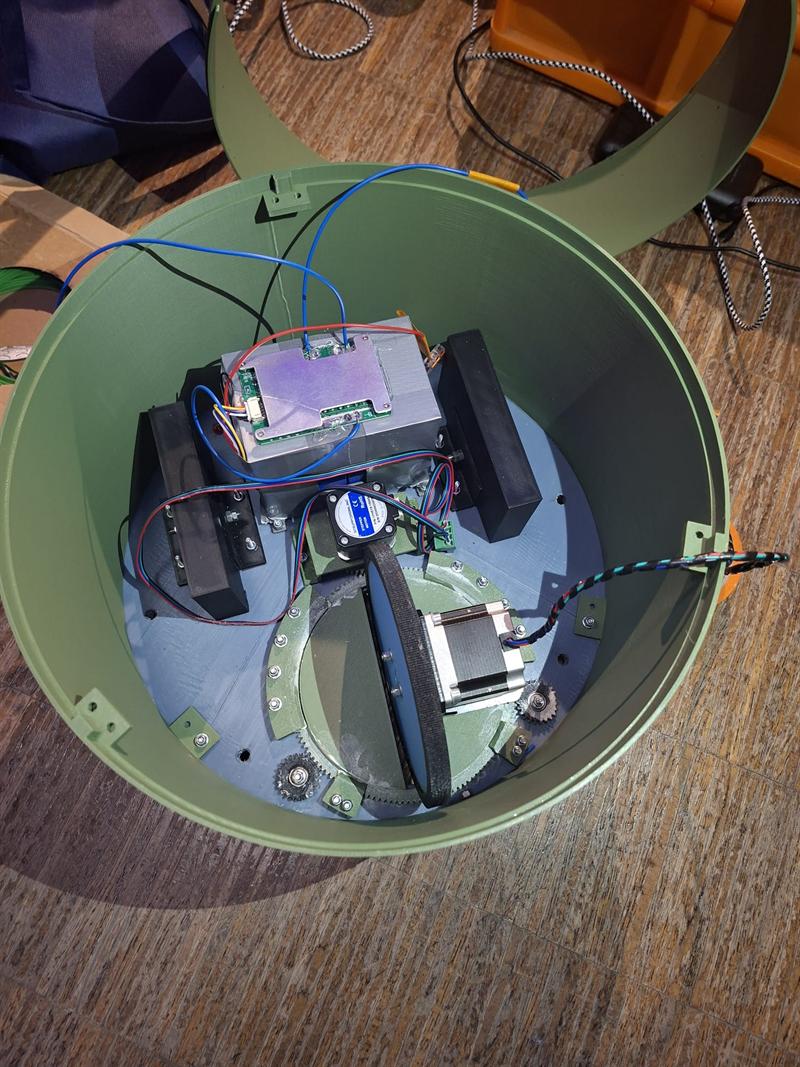
Under the hood
The housing and gears are 3D-printed in-house. Everything else we wired, programmed and tested during the night.
- Drive
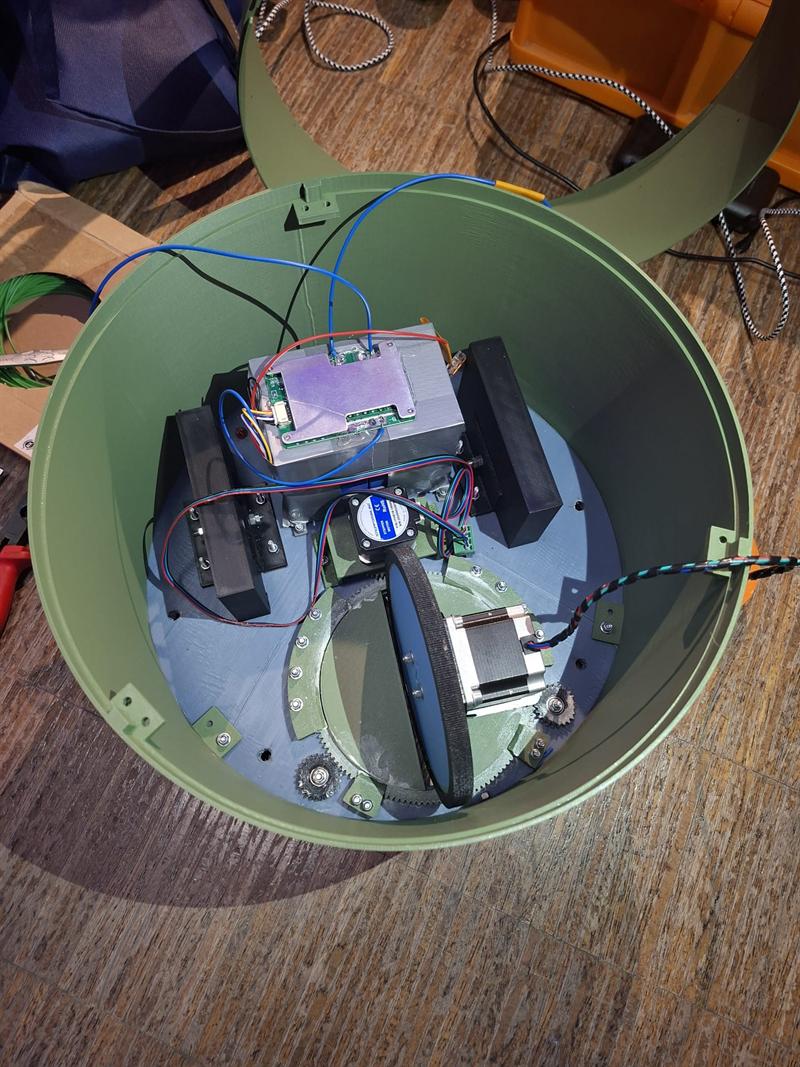
- A trike with two fixed rear wheels and one steered, driven front wheel.
- Navigation
- Lidar and an IMU build the map of the room (ROS 2, slam_toolbox, Nav2). Olli locates himself on it and drives to the table on his own.
- Electronics
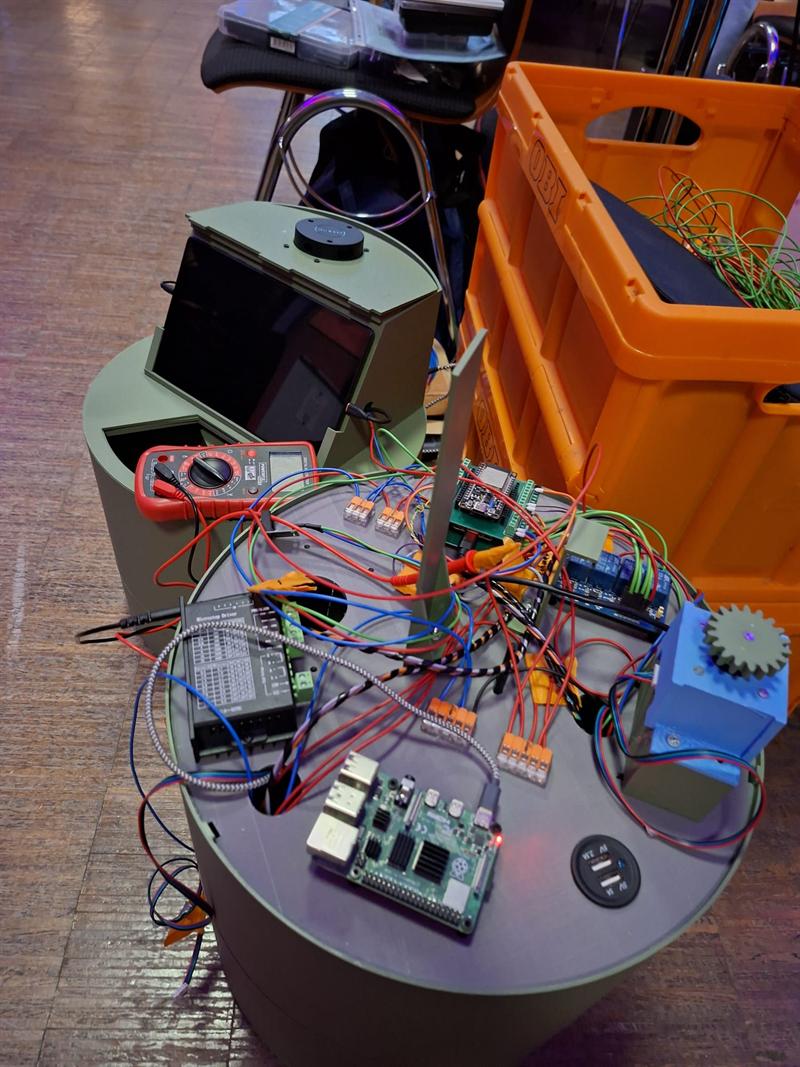
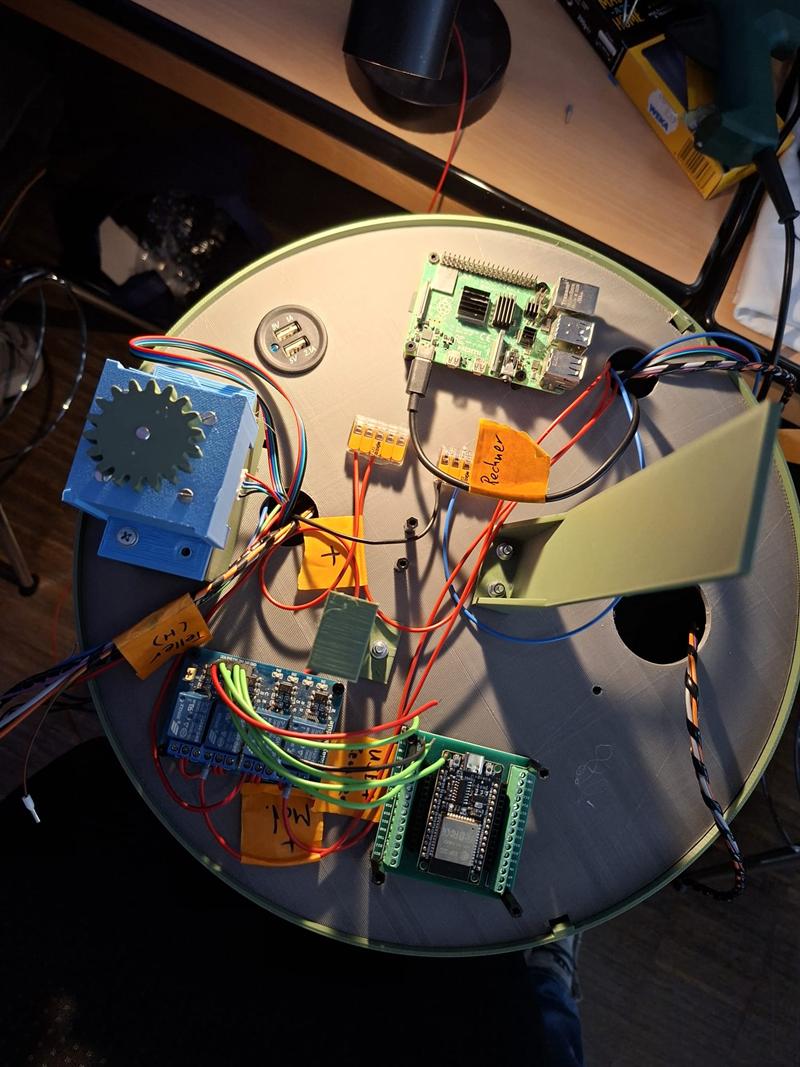
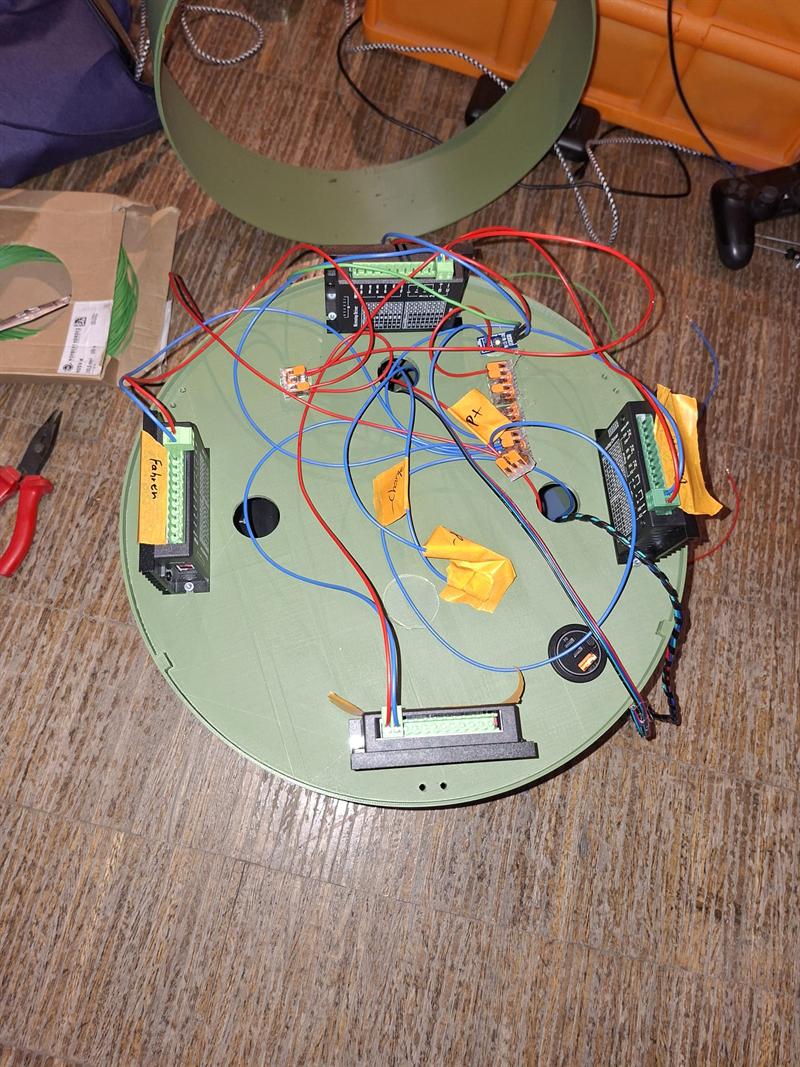
- An ESP32 controls motors, carousel and sensors. A Raspberry Pi 4 reads the lidar, a mini PC handles map, navigation and orders.
- Carousel
- Six compartments. Sensors detect whether a drink is in the compartment and whether a hand reaches in.
- Safety
- A stop button in the interface, an emergency brake if the drive command is lost and a front distance sensor.
- Face and voice
- A tablet shows the eyes. Whisper understands German, Piper speaks and Ollama provides the answers, all locally on a GPU PC.
- Dashboard
- Order queue, map, voltage, steering and sensors live in the browser.
From the event
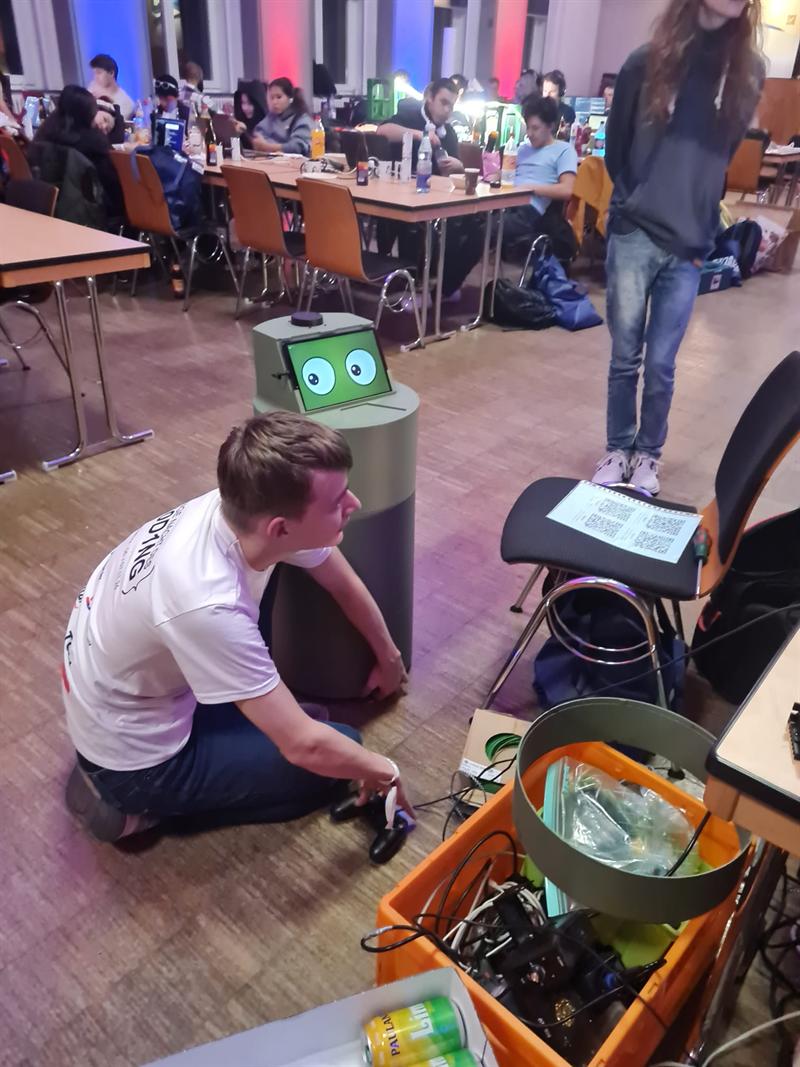
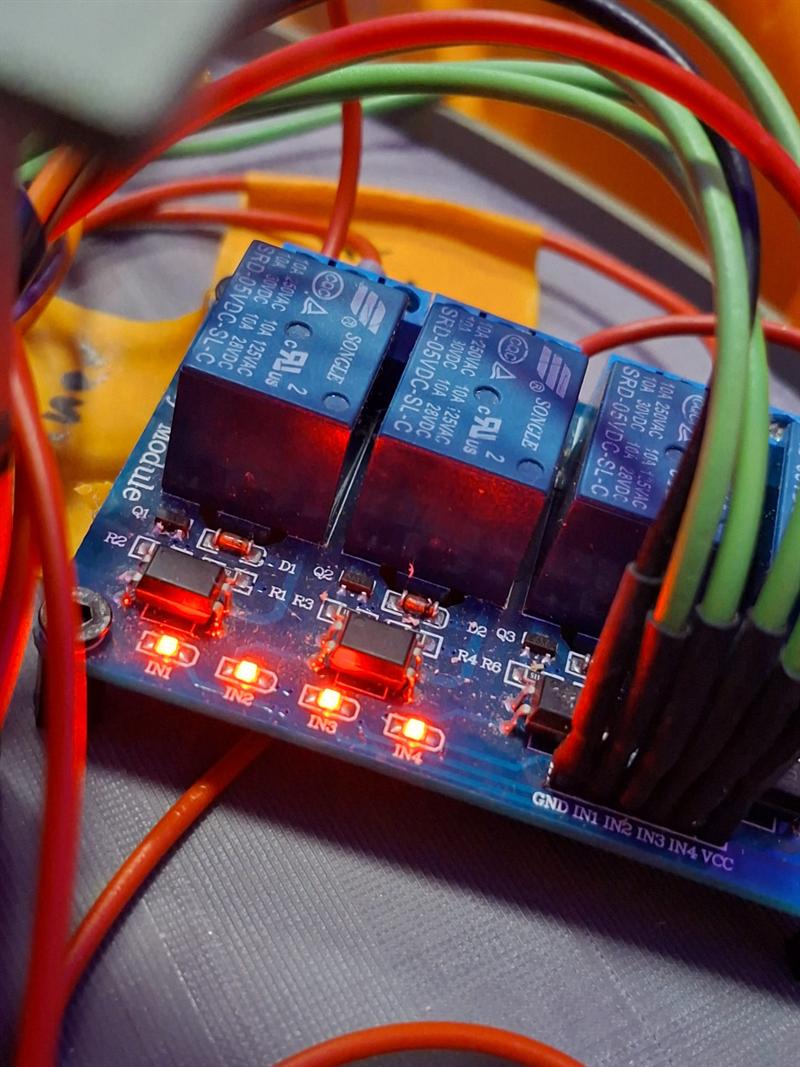
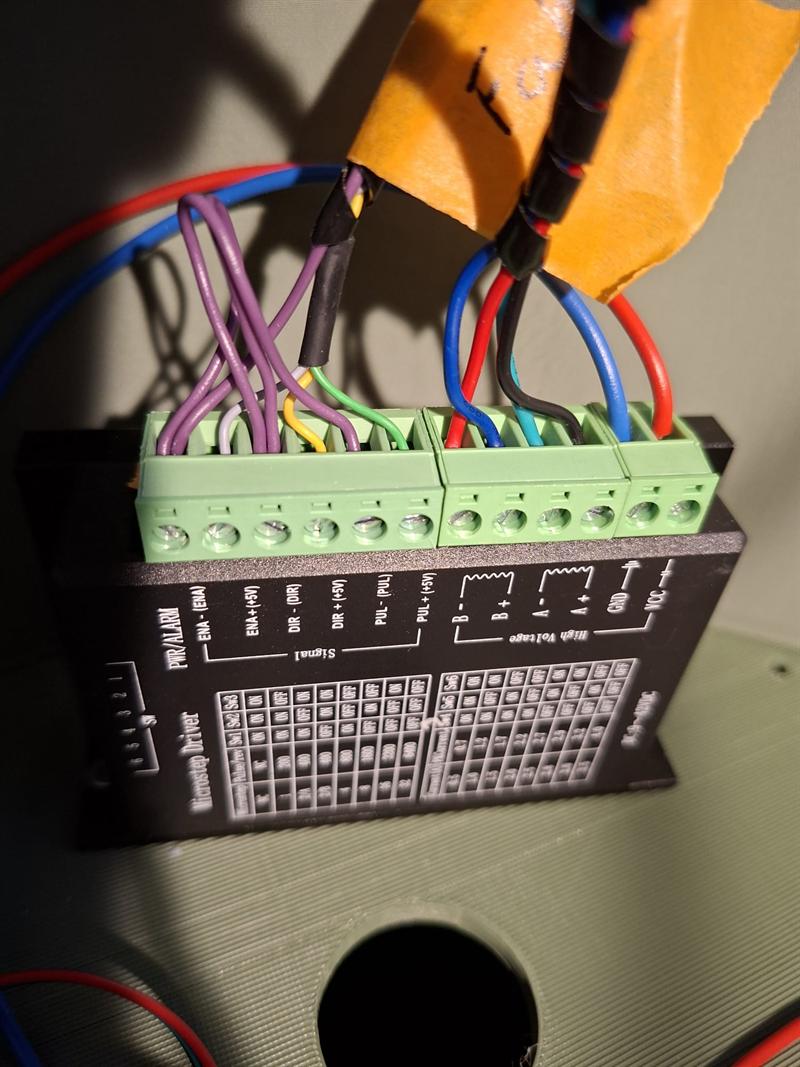
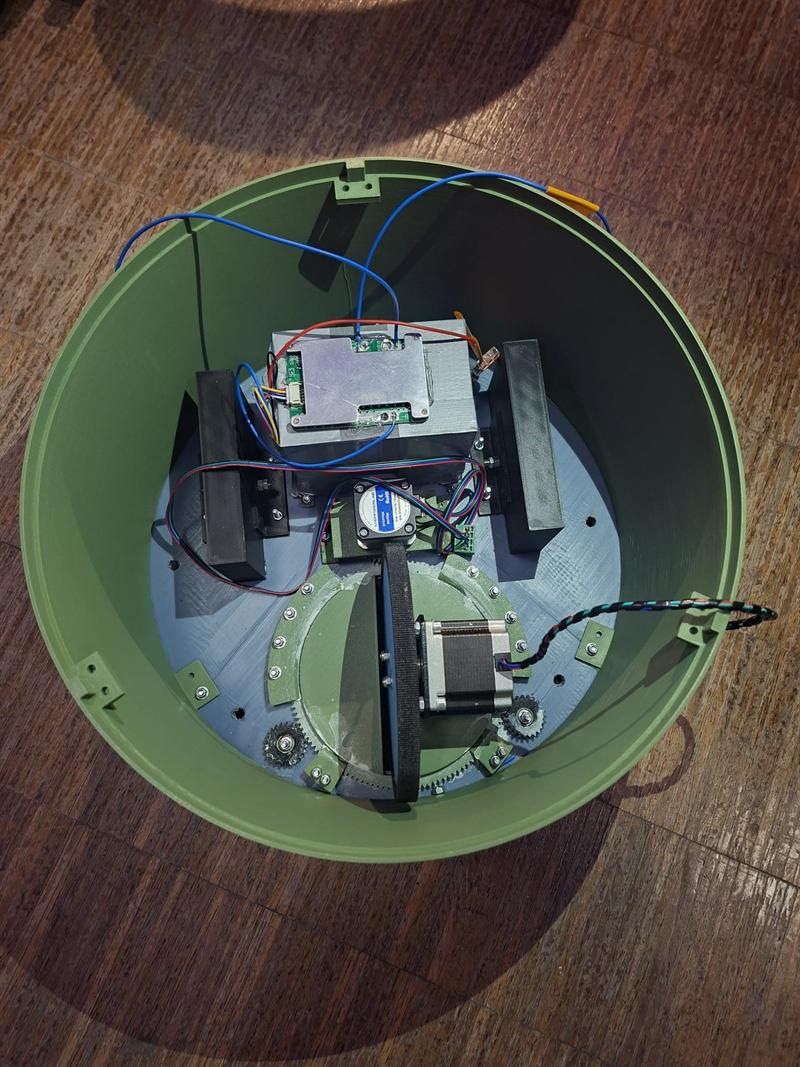
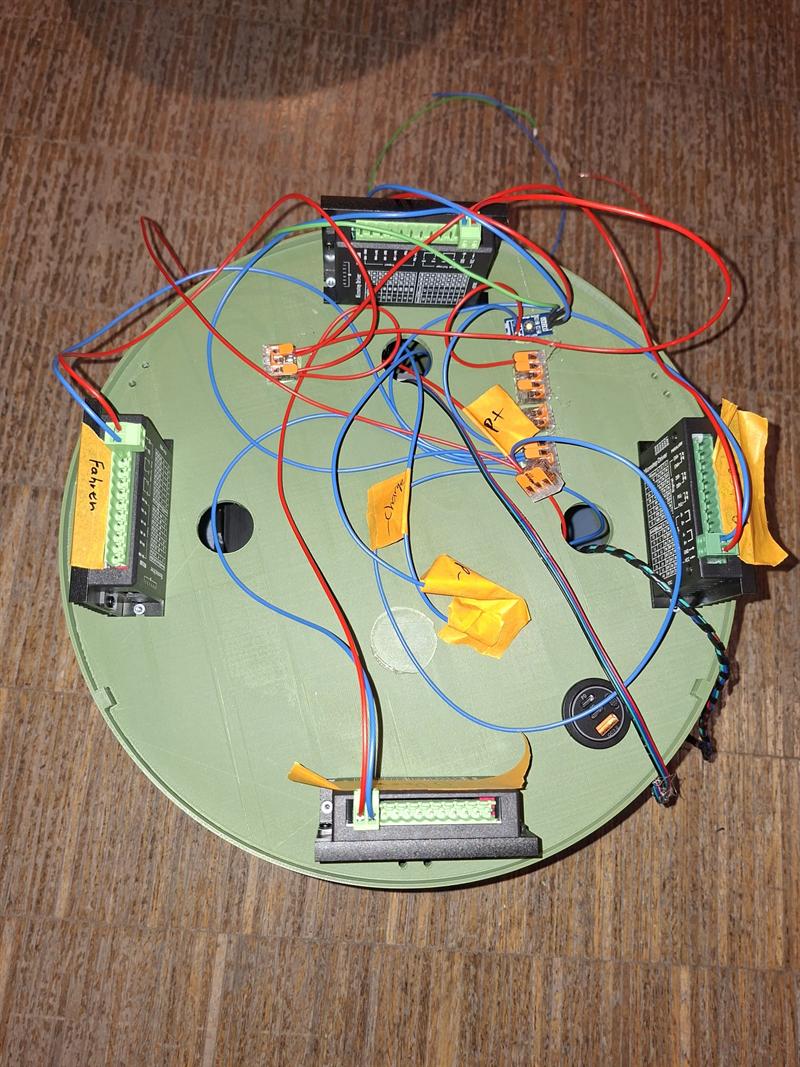
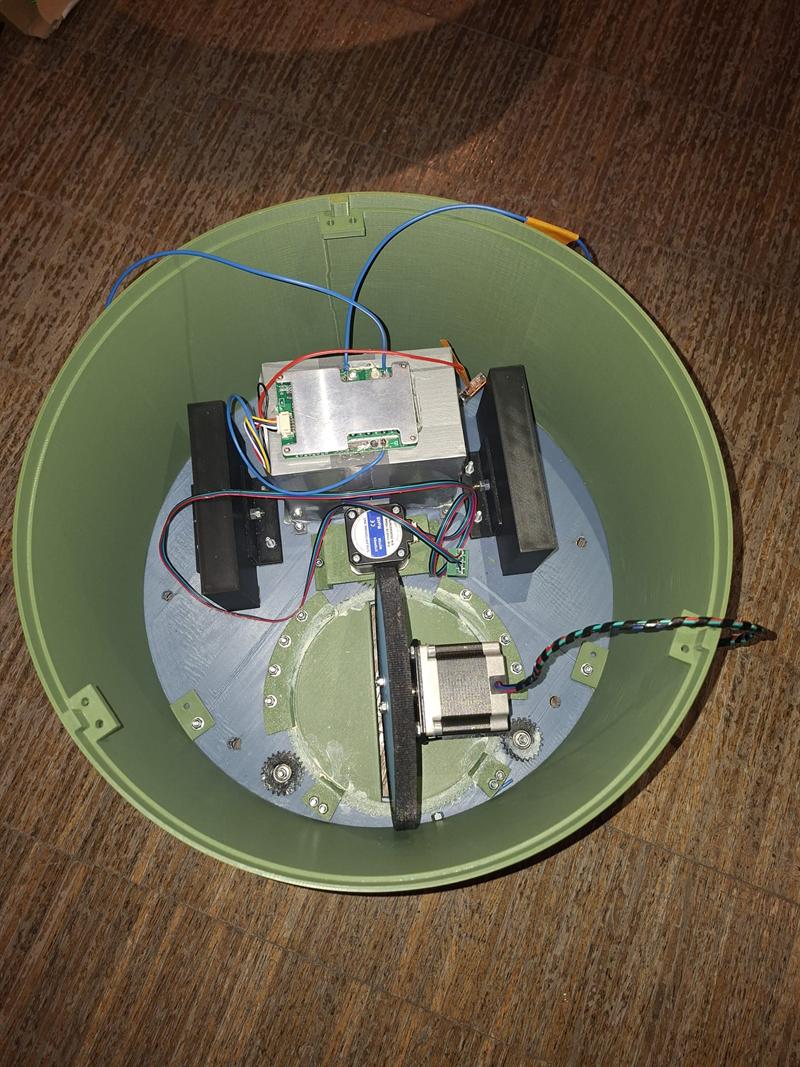
Olli at the Long Night of Coding, from the first wiring to the live demo. Click to enlarge.

Sponsors
Thank you to everyone who makes Olli possible.
The filament for Olli's 3D-printed housing, gears and mounts comes from SUNLU.
Help Olli grow
We want the prototype to become a lasting ambassador for technology and young talent. Here is what we need:
- Hardware and materialsStronger motors, batteries, sensors and filament.
- Visibility for youYour logo on Olli and on this page, at events and on social media.
- AppearancesOlli greets guests at your events or trade-fair booth.
- Supporting young talentStudents learn on a real project.